

CANmod.gps: GPS to CAN Module with Motion Data
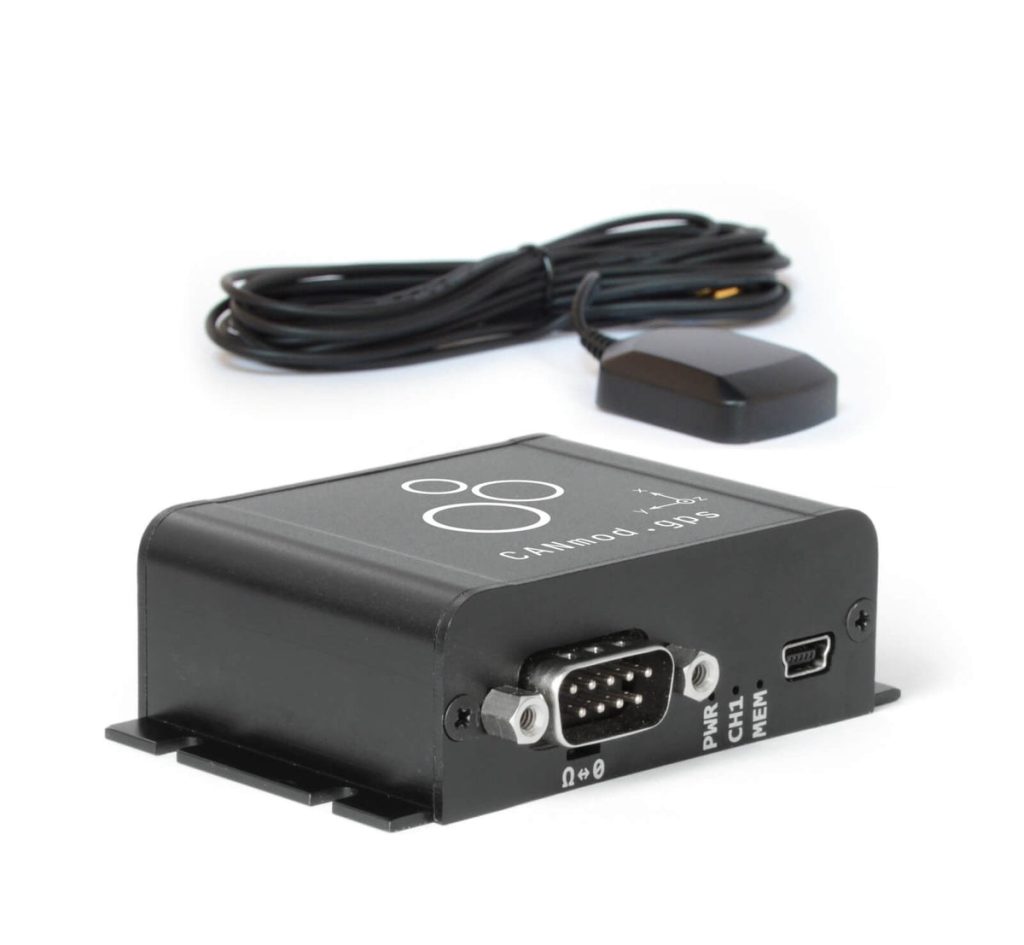
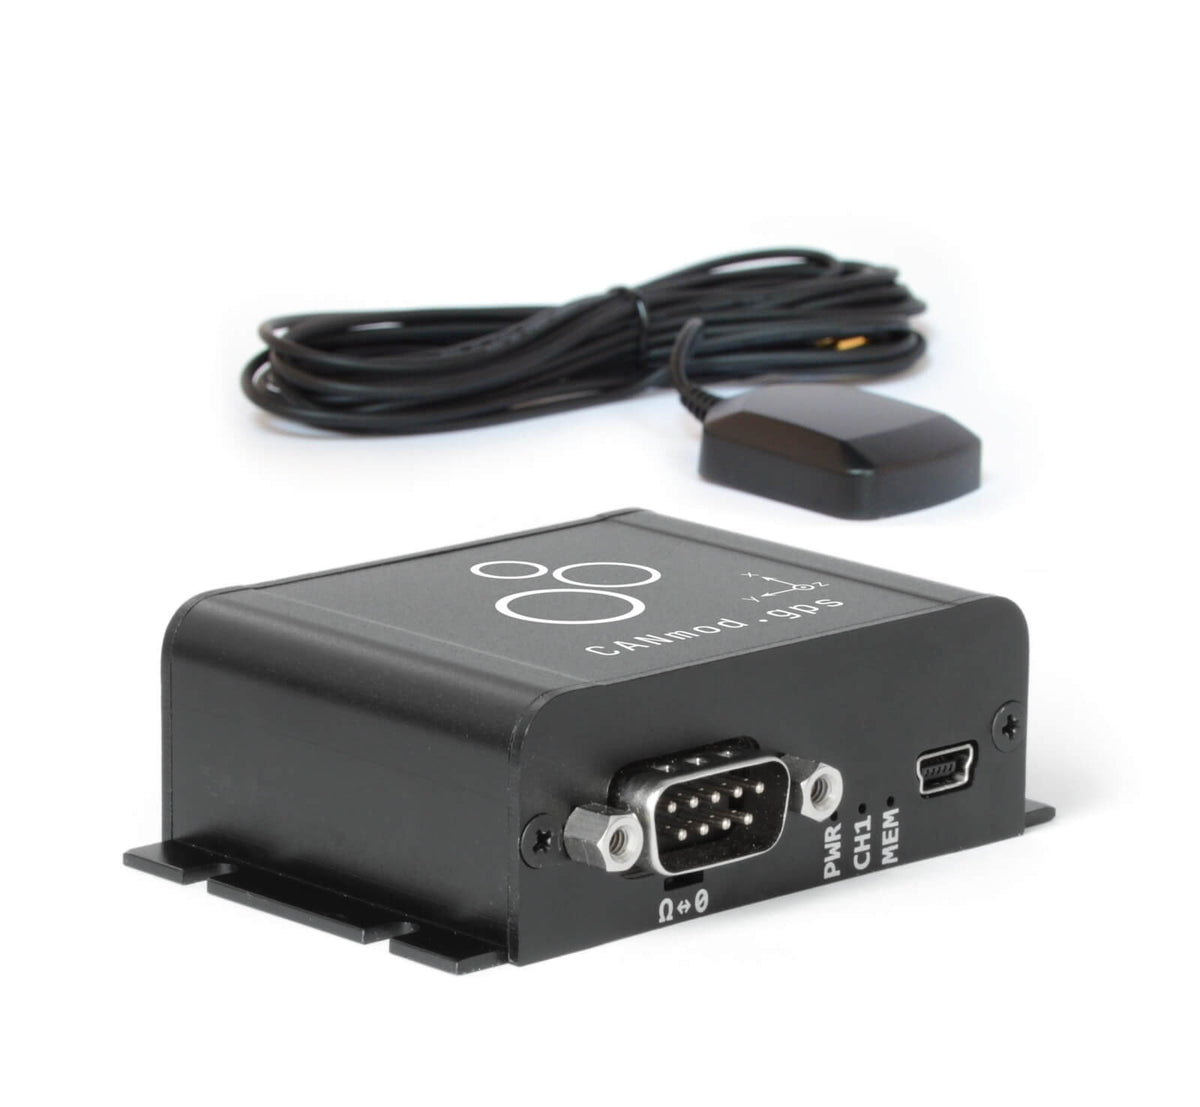
The CANmod.gps is a GPS to CAN module with a built-in inertial sensor. Location, speed, heading and acceleration add context to any vehicle log: where a fault happened, how hard the brakes were applied, which route a machine took. The CANmod.gps produces all of it and sends it as CAN messages, so any logger or ECU on the bus can use it.
It is built around a u-blox NEO-M8U receiver with a built-in gyroscope and accelerometer. In vehicles, sensor fusion (untethered dead reckoning) keeps the position accurate through tunnels, parking garages and urban canyons where satellite reception drops.
Highlights
- u-blox NEO-M8U GNSS with 3D gyroscope and accelerometer
- GPS, Galileo, BeiDou and GLONASS
- Dead reckoning (UDR) for vehicles: positioning through signal loss
- 2.5 m CEP position accuracy; 1 s reacquisition
- Up to 4 configurable geofences, reported via CAN
- GPS antenna included; DBC file for decoding included
Where it earns its keep
- Vehicle and fleet logging: add position, speed and route to CANedge J1939 or OBD2 logs
- Driving dynamics: capture acceleration, rotation and heading during tests
- Machines and agriculture: record where and how equipment operates
- Geofencing: trigger events when a vehicle enters or leaves an area
Key Specifications
| Spec | Value |
|---|---|
| Function | Outputs GNSS position and IMU motion data on CAN (or USB) |
| Receiver | u-blox NEO-M8U, 72 channels, built-in gyroscope and accelerometer |
| Constellations | GPS, Galileo, BeiDou, GLONASS (and combinations) |
| Sensor fusion | Untethered dead reckoning (UDR) of GNSS and IMU, for automotive use |
| Accuracy | 2.5 m CEP (position) |
| Time to fix | Cold start 26 s, aided start 3 s, reacquisition 1 s |
| Sensitivity | Tracking -160 dBm, cold start -148 dBm, hot start -157 dBm |
| Geofences | 0-4 circular geofences, status via CAN |
| CAN output | 1 x CAN up to 1 Mbit/s; configurable IDs (11/29-bit), push or poll, message rates |
| Connector | DB9 (CAN and power) |
| Antenna | GPS antenna included (SMA, 3 m cable, magnetic base) |
| Enclosure | Aluminium, 65 x 48 x 24 mm, 70 g, 4 LEDs |
| Power | +5 to +26 V DC via the DB9 connector (pin 1 or 9); under 1 W |
| Configuration | JSON configuration files (same concept as the CANedge), via USB |
| USB | Mini USB for configuration, firmware updates and live streaming |
| Operating temperature | -25 °C to +70 °C |
| IP rating | IP40 |
| Made in | Denmark |
Frequently asked questions
Do I need the CANmod.gps if my CANedge already has GPS?
The CANedge1, CANedge2 and CANedge3 variants with GNSS/IMU have position data built in. The CANmod.gps is for loggers or systems without it, such as other CAN loggers, ECUs or interfaces, or when you need the data shared on the CAN bus itself.
Does a CANmod need a PC or a logger to work?
No. Once configured, it runs on its own from the DB9 power pins and puts its data straight onto the CAN bus. A PC is only needed over USB to change the configuration, update firmware or watch the data live.
How do I decode the CAN messages it sends?
CSS Electronics provides a DBC file describing every message and signal the module outputs, so any DBC-capable tool, including the CANedge software and asammdf, shows the values directly in engineering units.
Need a quote or help choosing the right setup? Contact Pertech, the CSS Electronics distributor in Israel.
